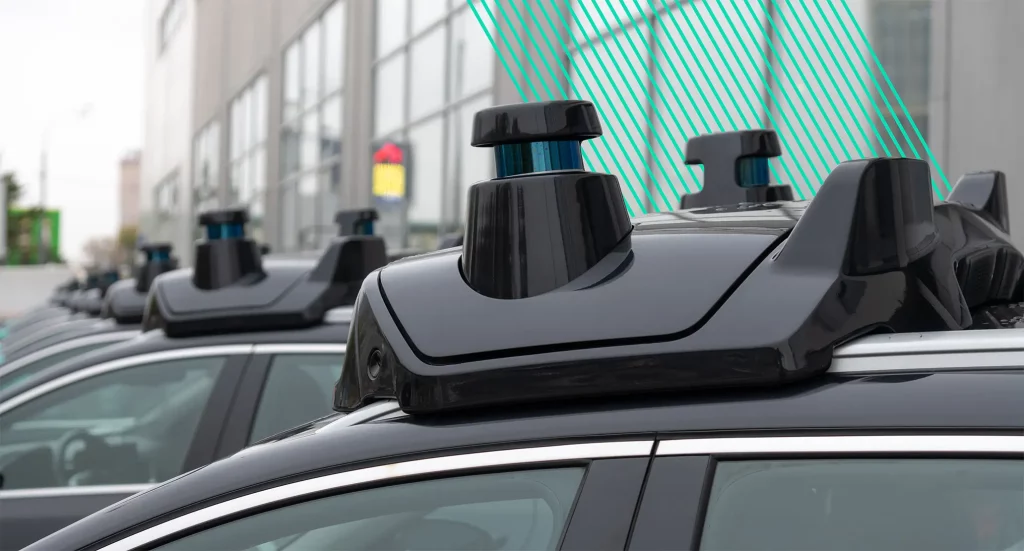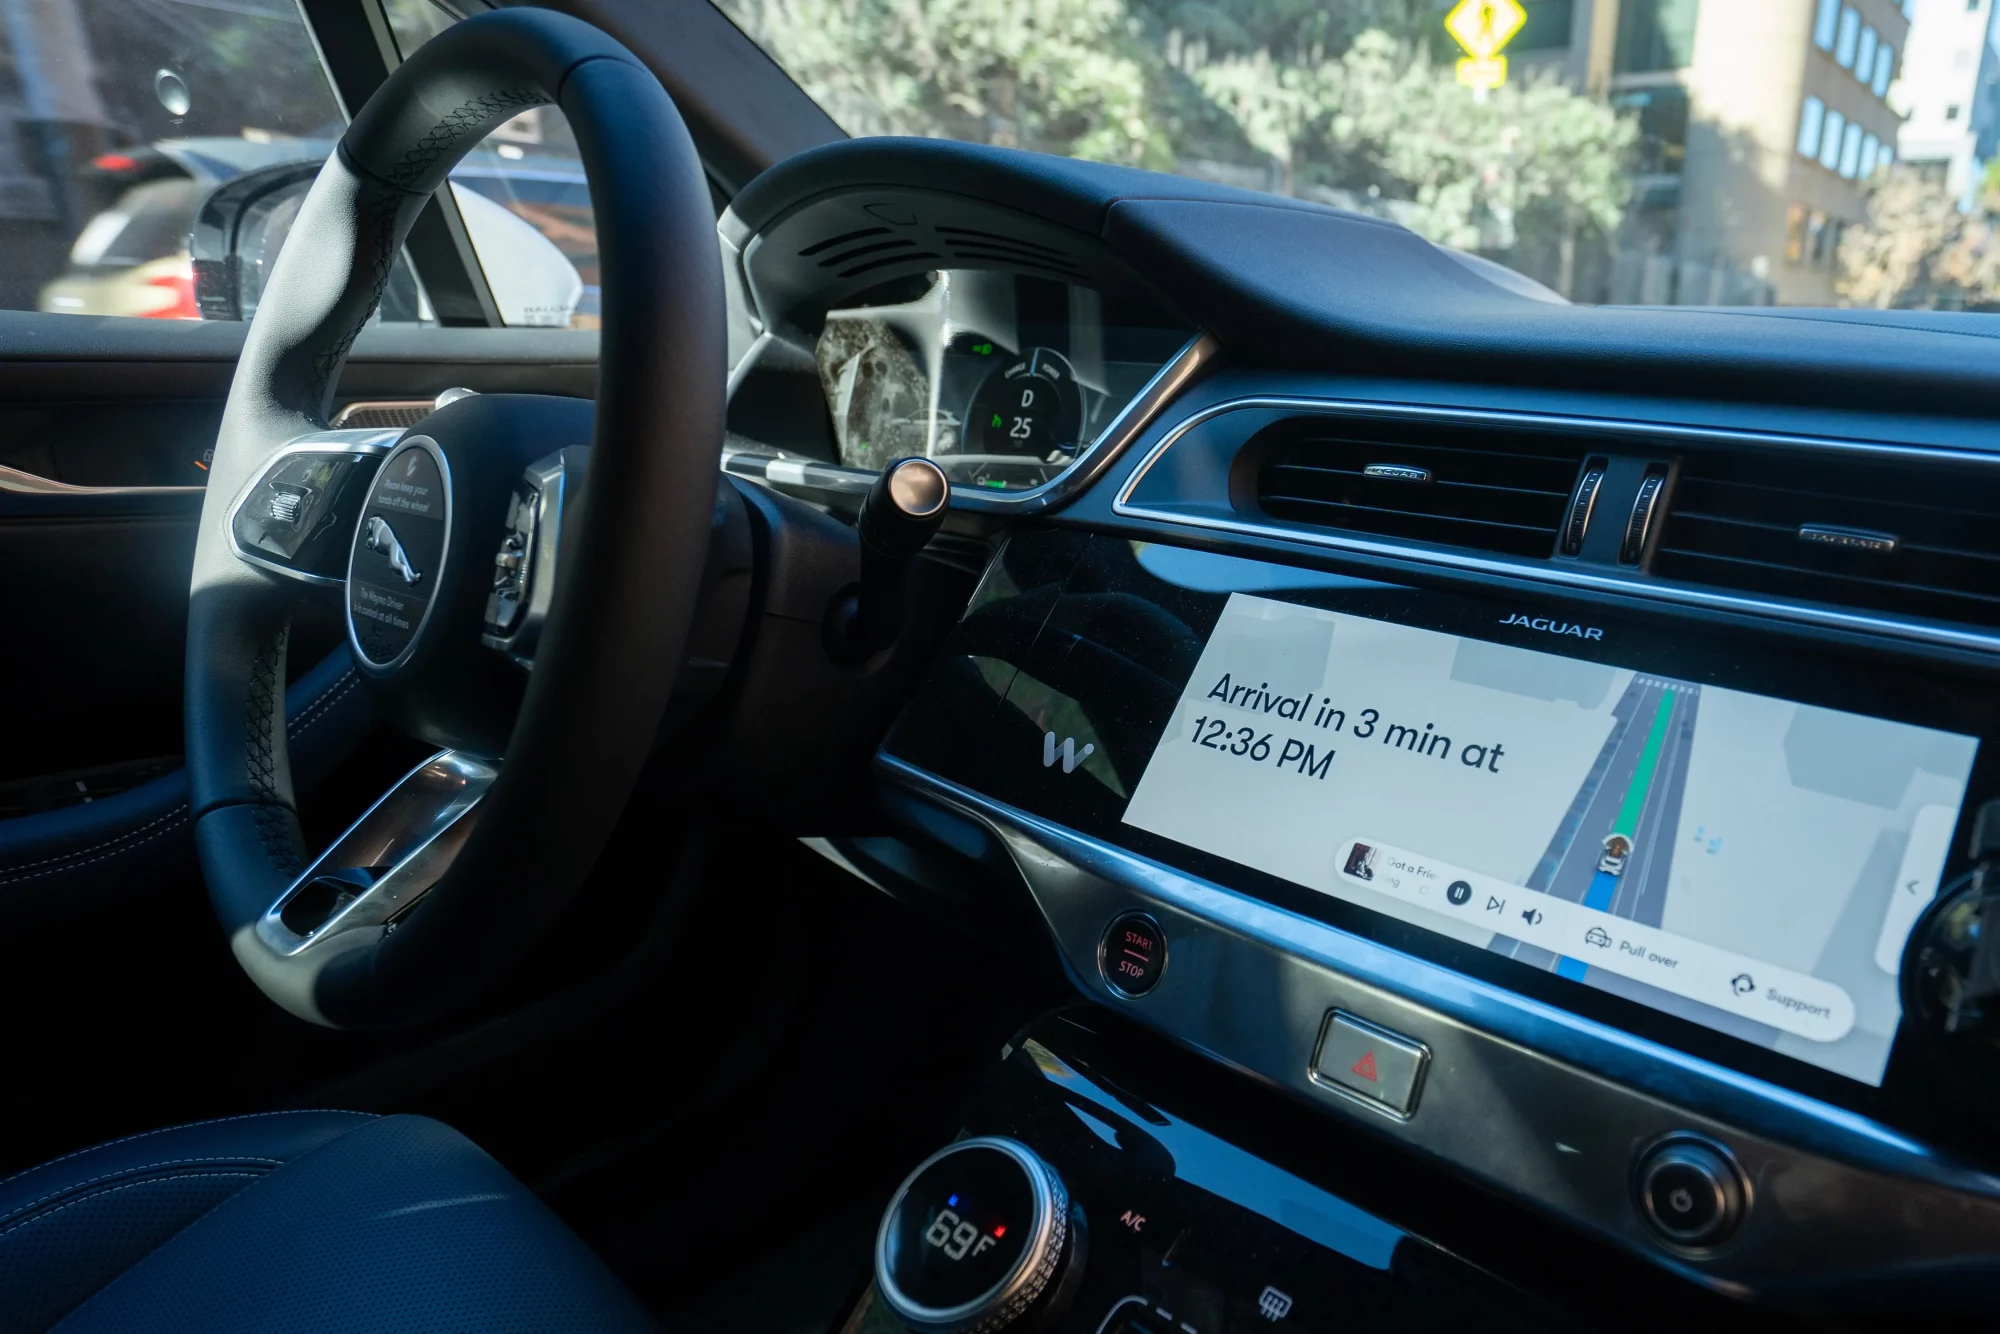

Every driverless service operates inside a boundary called the operational design domain, and how fast that boundary grows decides how fast a fleet scales.
Ask how good a robotaxi is at driving and you’ll get a number: miles driven, crashes avoided, a figure lifted from a press release. It’s the wrong question. The better one is where the vehicle is allowed to drive, and under what conditions, because that boundary shapes the industry more than the AI model or the sensor stack ever will.
What the boundary actually specifies
Every autonomous driving system comes with a formal statement of where and when it’s designed to work. The industry calls it the operational design domain, or ODD, and it sits at the heart of SAE J3016, the standard that defines the levels of driving automation. A Level 4 vehicle, the kind that drives with no human at the wheel, does so only inside its ODD. That limit is part of the definition, not a flaw in it.
An ODD isn’t a loose idea of “good conditions”. It’s an engineered boundary with specific dimensions:
- Geography: named roads and zones, defined down to the street segment
- Road types: surface streets, highways, both or neither
- Weather: thresholds for rain, fog, snow and wind
- Time of day: daylight only, or day and night
- Traffic: dense urban, quiet residential, fast freeway merges
- Speed: the range the system has been validated to handle
Step outside any one of them and the system doesn’t perform a little worse. It simply hasn’t been validated to operate at all. A human who has only driven in California can still muddle through a Minnesota snowstorm, because human skill generalises. A Level 4 system whose ODD excludes snow doesn’t drive in snow. It stops, pulls over, or, with nobody aboard, never gets dispatched.

Cities first, weather last
Geography is the dimension companies widen on purpose, which is why Waymo’s growth reads as a city-by-city campaign. Every road needs a high-definition map that’s been built, validated and kept current, so each new city is a separately validated domain. The scale is now considerable: Waymo had driven nearly 200 million fully autonomous miles by February 2026, its covered area had grown past 1,400 square miles by May, and the Denver launch took it to 14 cities.
Weather expands far more grudgingly, and Denver is the test. The city averages about 56 inches of snow a year, against under five in Nashville, Waymo’s previous coldest city. Waymo hasn’t said its cars will drive in snow. It says its vehicles are designed to come to a safe stop if conditions deteriorate, which is the boundary doing exactly what it’s meant to do. Detroit followed this week, when Waymo put driverless cars on the city’s streets with employees as the only riders.
Freight shows the method
Aurora’s trucks show how a domain widens one variable at a time. The company has shipped four software releases since launching its driverless trucks in April 2025, and each one extended the ODD: Dallas to Houston first, then night driving, then El Paso, then the wider Sun Belt. Night operations began three months after launch. The network has since grown from three routes to ten, including a lane of roughly 1,000 miles between Fort Worth and Phoenix. Each step was a bigger domain, validated before anyone sold it.
The domain is also a licence
Regulators treat the ODD as the thing they approve, and that’s what turns “scaling” into a sequence of sign-offs. In California, the DMV reviews and approves a company’s ODD, which covers geography, time of day, roadway type and weather. Charging fares is a separate matter, because the CPUC regulates passenger service. The CPUC approved Waymo’s updated passenger safety plan for its expanded ODD in August 2026. That’s two regulators and two approvals for one wider map.
Europe goes further. Under Regulation (EU) 2022/1426, the weather envelope is part of a type-approved ODD, and the vehicle must perform a minimum risk manoeuvre when it reaches the boundary. Waymo has started mapping Munich for a service it wants running by late 2027. The engineering question is the same on both continents, but in Europe a regulator has to agree with the answer.
The Gulf writes the ODD straight into the permit. WeRide’s Abu Dhabi permit removed the in-vehicle safety officer and defined a 110-kilometre operating area with around 460 stops at speeds up to 80 km/h. You could lift that sentence straight into an ODD specification.
Scaling is a ladder of approvals
The route from a few streets to a whole city isn’t one leap. It starts with a provisional ODD, a hypothesis about the streets, speeds and conditions a company believes it can handle. Human-driven vehicles then work that footprint, building the map and logging how traffic really behaves. The vehicle drives it autonomously with a safety operator aboard, and the domain gets reshaped by what that reveals: an ambiguous merge is carved out, a speed threshold drops, a weather condition that looked viable gets excluded. A formal safety case then argues that the system meets the bar for removing the human, and a regulator has to agree. Only then does the next rung come into view.
That changes the question for any operator. It’s no longer “how well do we drive?” but “how quickly can we evidence the next rung?” Every widening, whether a new city, a new weather condition or a new road type, needs proof that the safety case holds and an approval to match. The operators that scale fastest treat the domain as an asset they grow deliberately. The ones that stall treat it as a gate they cleared once.
Frequently asked questions
What is an operational design domain (ODD)?
An operational design domain is the formal statement of where and when an autonomous driving system is designed to work. It is defined in SAE J3016, the standard that sets out the levels of driving automation, and covers geography, road types, weather, time of day, traffic and speed.
What happens when a robotaxi reaches the edge of its operational design domain?
The system has not been validated to operate beyond its ODD, so it stops, pulls over or, with nobody aboard, is never dispatched. In Europe, Regulation (EU) 2022/1426 requires the vehicle to perform a minimum risk manoeuvre when it reaches the boundary.
Can robotaxis drive in snow?
Only where snow falls inside the vehicle’s ODD. Waymo has launched in Denver, which averages about 56 inches of snow a year, but has not said its cars will drive in snow. Its vehicles are designed to come to a safe stop if conditions deteriorate.
Why do robotaxi services launch one city at a time?
Every road in a service area needs a high-definition map that has been built, validated and kept current, so each new city is a separately validated domain. Waymo’s Denver launch took its service to 14 cities, and its covered area had grown past 1,400 square miles by May 2026.
Who approves a robotaxi’s operational design domain?
That depends on the jurisdiction. In California, the DMV reviews and approves a company’s ODD and the CPUC separately regulates paid passenger service, approving Waymo’s updated passenger safety plan for its expanded ODD in August 2026. In the EU, the ODD and its weather envelope form part of type approval under Regulation (EU) 2022/1426.
What does a driverless robotaxi permit specify?
A permit can set out the ODD directly. WeRide’s Abu Dhabi permit removed the in-vehicle safety officer and defined a 110-kilometre operating area with around 460 stops at speeds up to 80 km/h.
How do autonomous trucks expand their operational design domain?
They add one variable at a time and validate each step before it goes into commercial service. Aurora has shipped four software releases since launching driverless trucks in April 2025, adding night driving, El Paso and the wider Sun Belt to its first Dallas to Houston route, and its network has grown from three routes to ten.
How does a robotaxi operator scale from a few streets to a whole city?
The operator starts with a provisional ODD, maps it with human-driven vehicles and then drives it autonomously with a safety operator aboard, reshaping the domain as problems appear. A formal safety case must then convince a regulator that the human can be removed, and each later widening needs fresh evidence and a matching approval.
Speak to the Cubic team to explore how our connectivity platform supports autonomous vehicle and advanced mobility deployments.